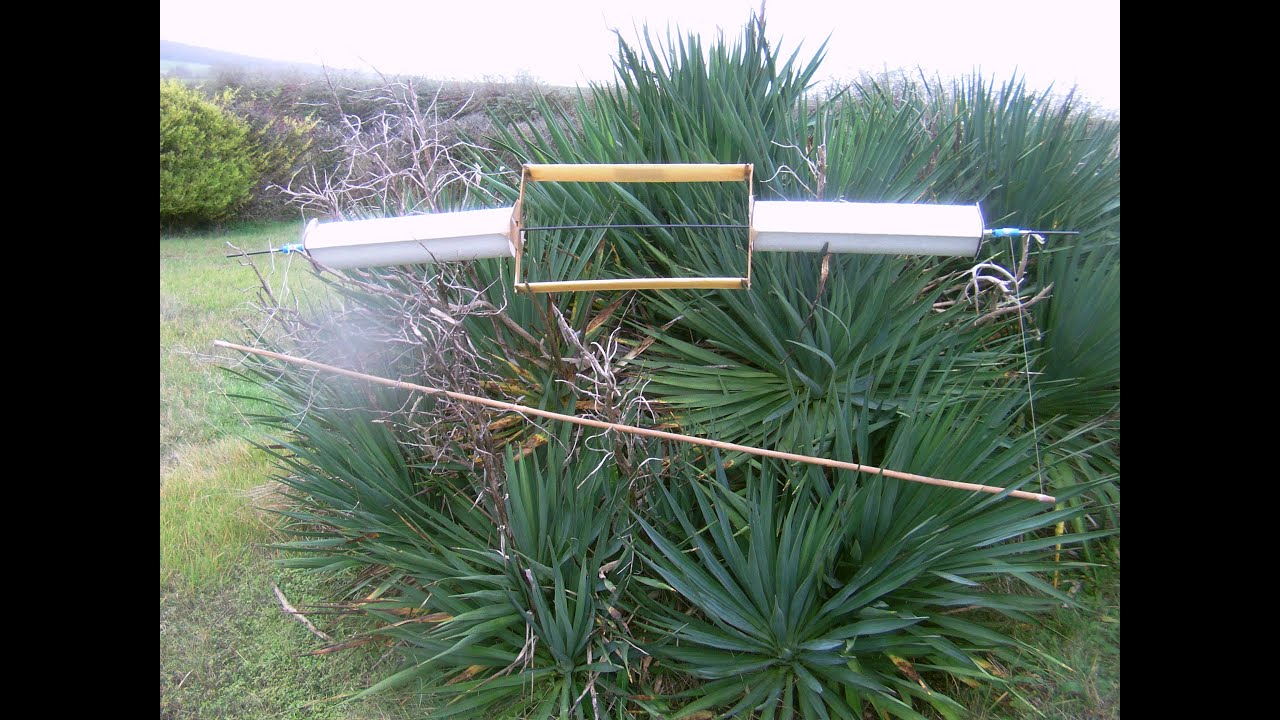
Things are starting to clear up a little. With the same device (two Sharp rotors framing a VAWT rotor), but a slightly higher wind speed (7-9 m/s) I obtained from time to time a slight positive elevation angle of 5 or 10 degrees . From a wind speed of 10 m/s, the elevation angle is expected to increase significantly.
Remember that with the Sharp rotor located in the VAWT, everything fell like a stone even with a wind speed greater than 10 m/s.
At high wind speed, the Sharp rotors are slowed down by this VAWT, whose TSR in strong winds decreases compared to the TSR of the Sharp rotor (which increases because the frictions are relatively less important), and becomes too low.
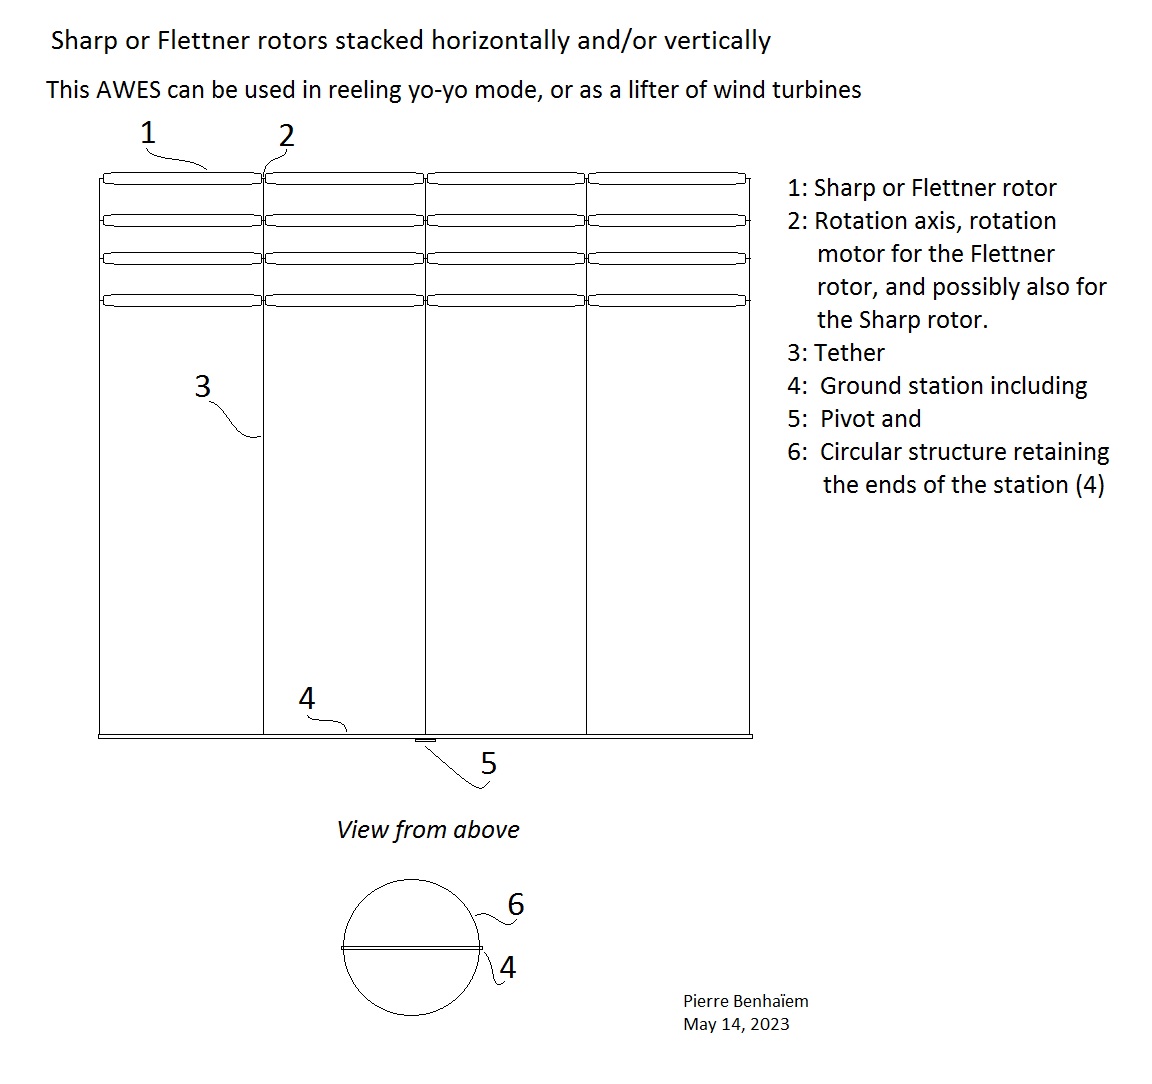
If these Sharp rotors include on their respective axes regenerative brakes used to stop or slow down the rotation for the reel-in recovery phase, the recovered energy can be used for lighting, signaling, and powering electronic devices such as sensors, and even speakers for music or for alarm.
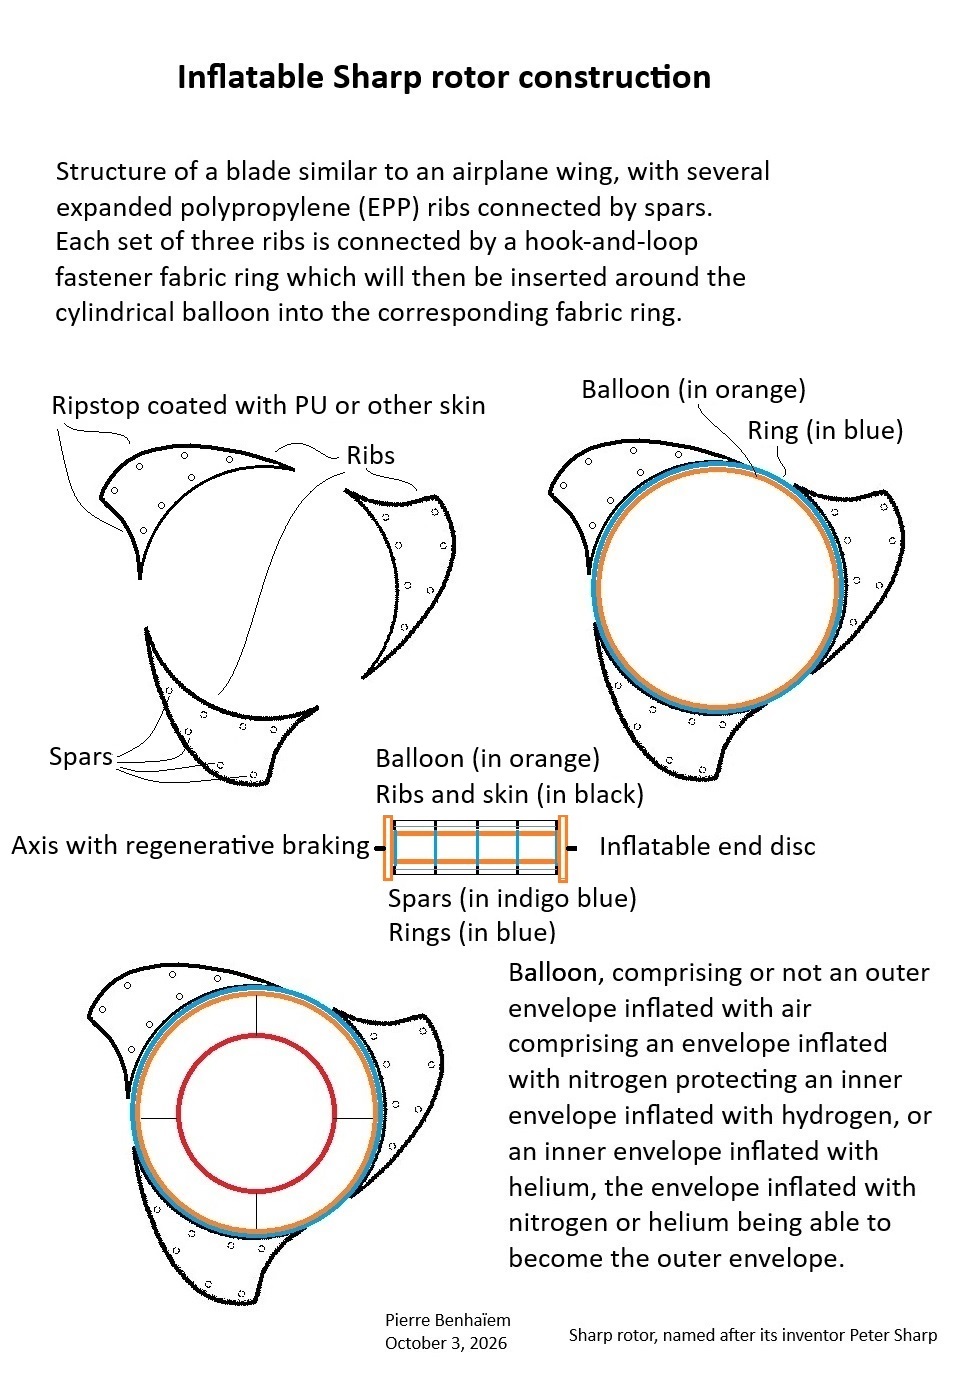
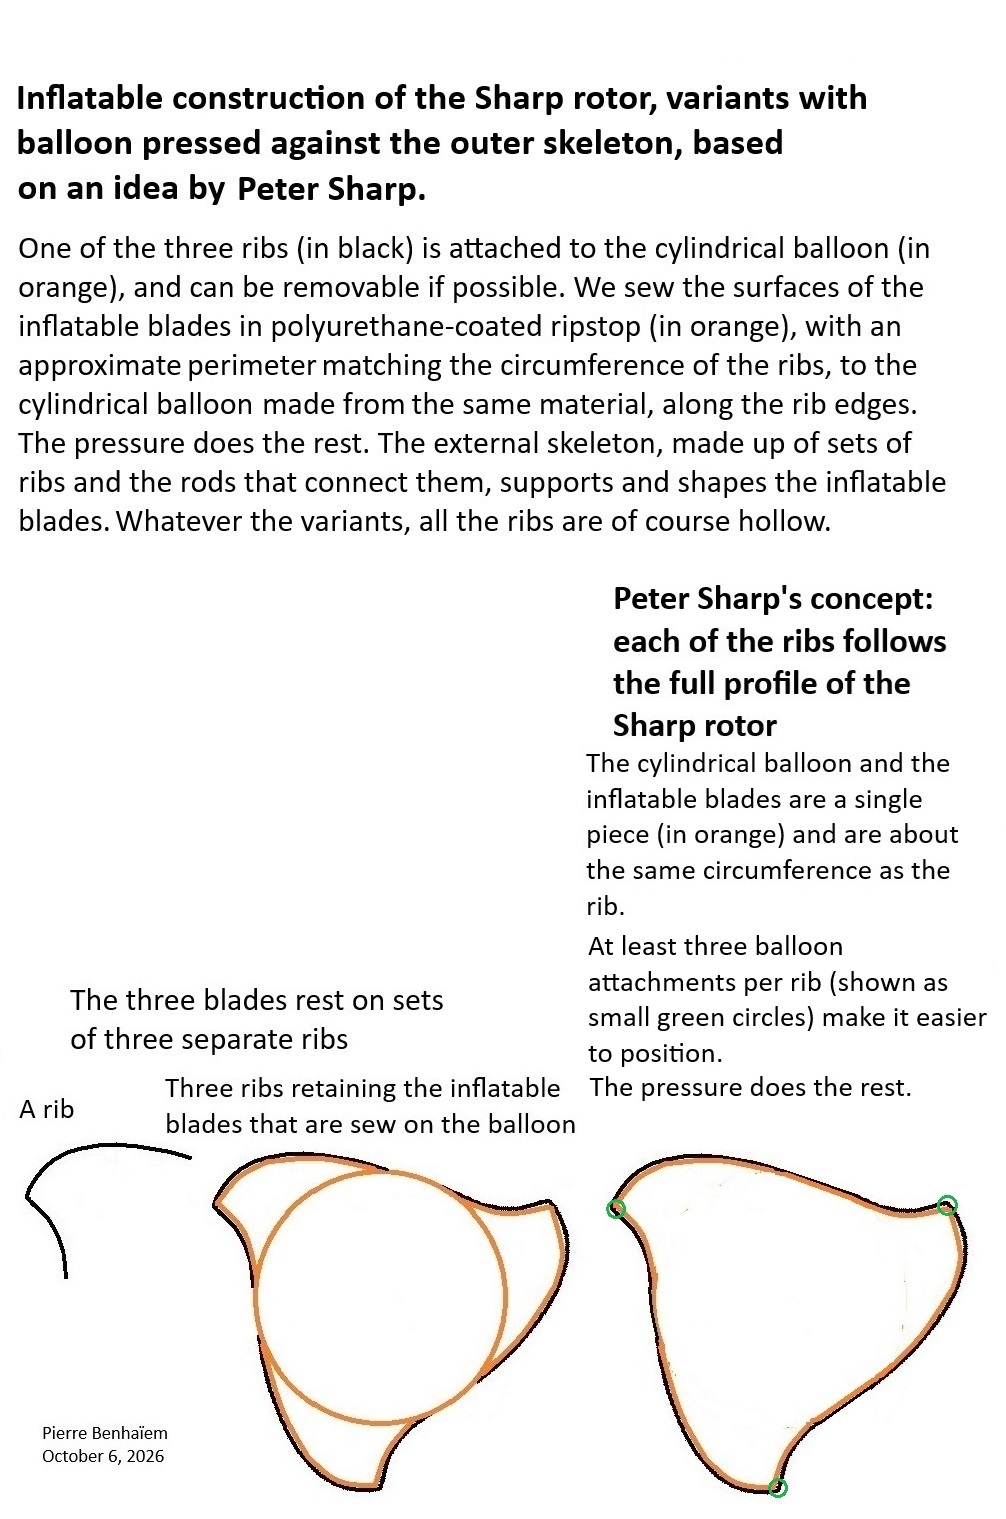
I think I’ve found a solution for an inflatable Sharp rotor.
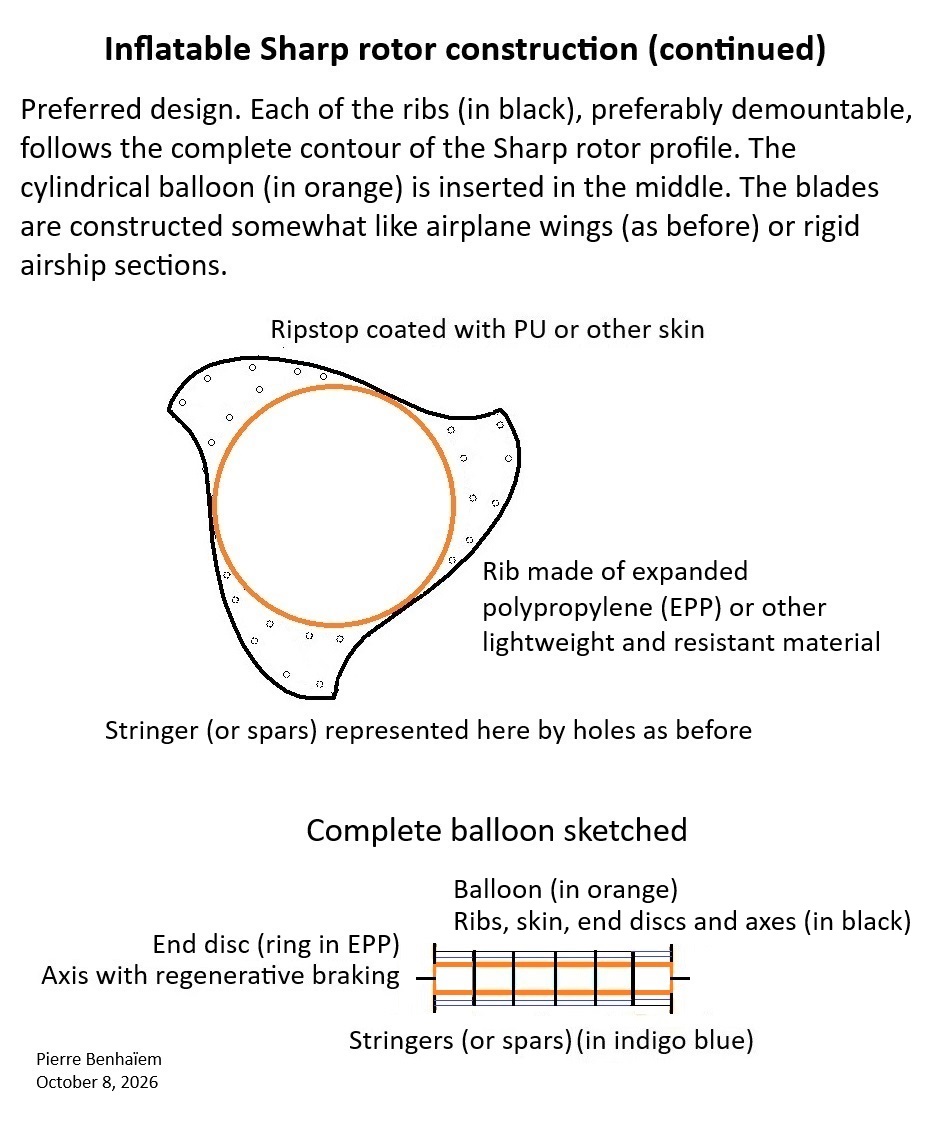
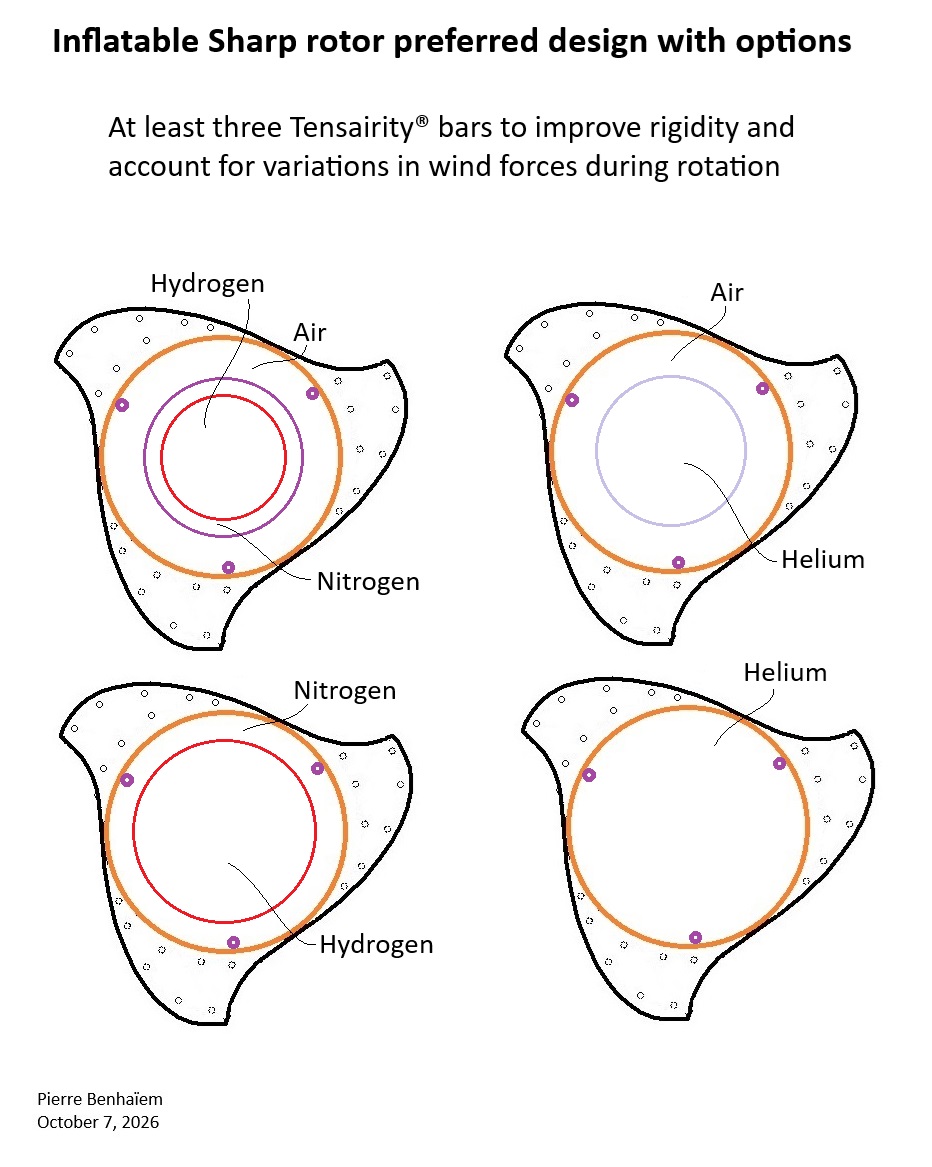
We can have a central cylindrical balloon whose diameter is roughly two-thirds of the total diameter. We construct each of the three blades separately, like airplane wings, with ribs (made of EPP), spars and skin. We connect them to a self-gripping fabric (Velcro) ring that we insert into the balloon, which is surrounded by the corresponding fabric ring. Self-rotating Magnus effect-based balloon in pumping mode or as a lifter (the end).